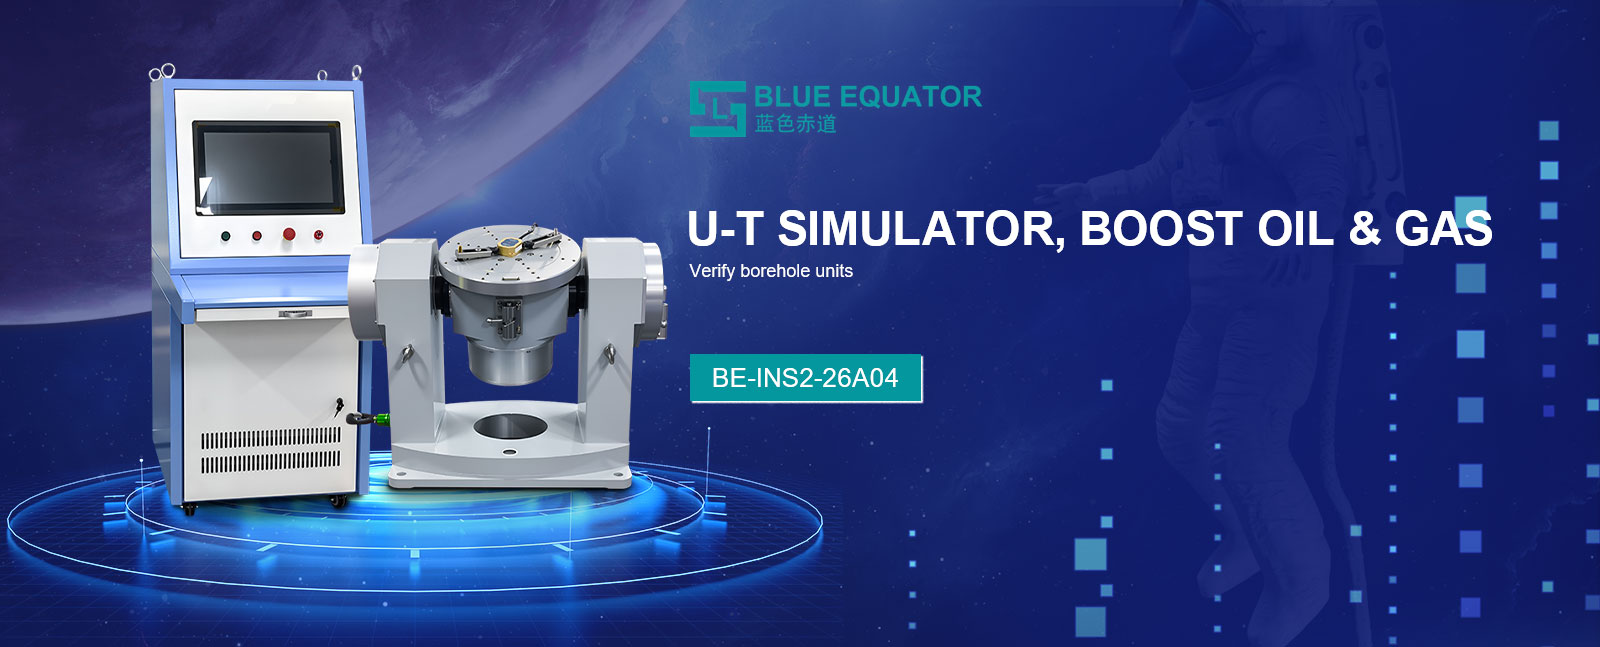
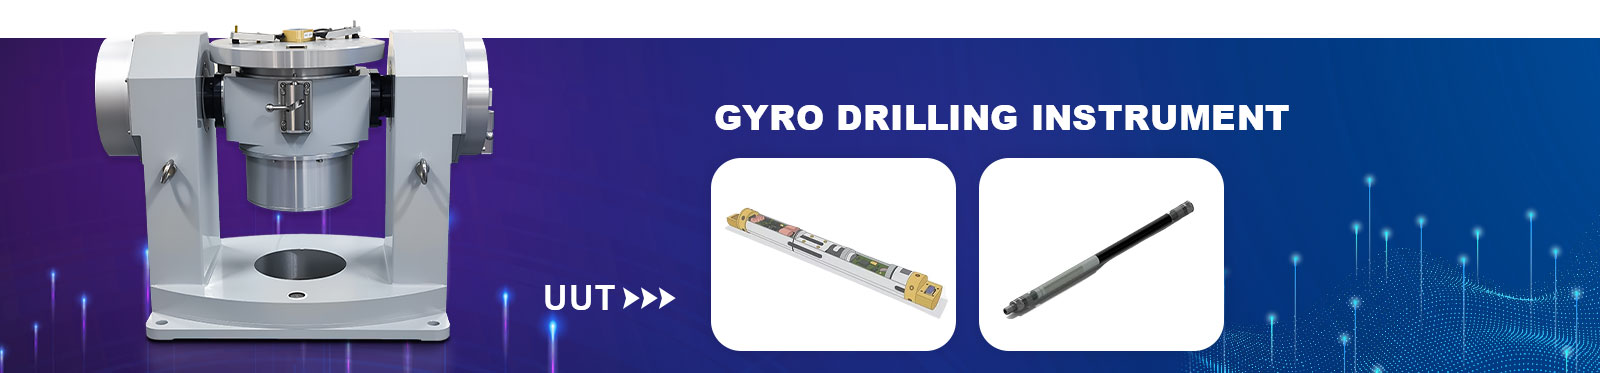
• Precision dual axis motion simulator for construction survey and lab research on bench
  • U-T calibration stand with ⌀320mm alloy platform and marble isolation base for teaching
  • Close up of high precision encoder for ±3 arcsec accuracy and ±2 arcsec repeatability
  • Motion simulator performing low speed drift test for engineering sensor calibration
  • Test equipment dimensions with 10kg capacity on research laboratory workbench
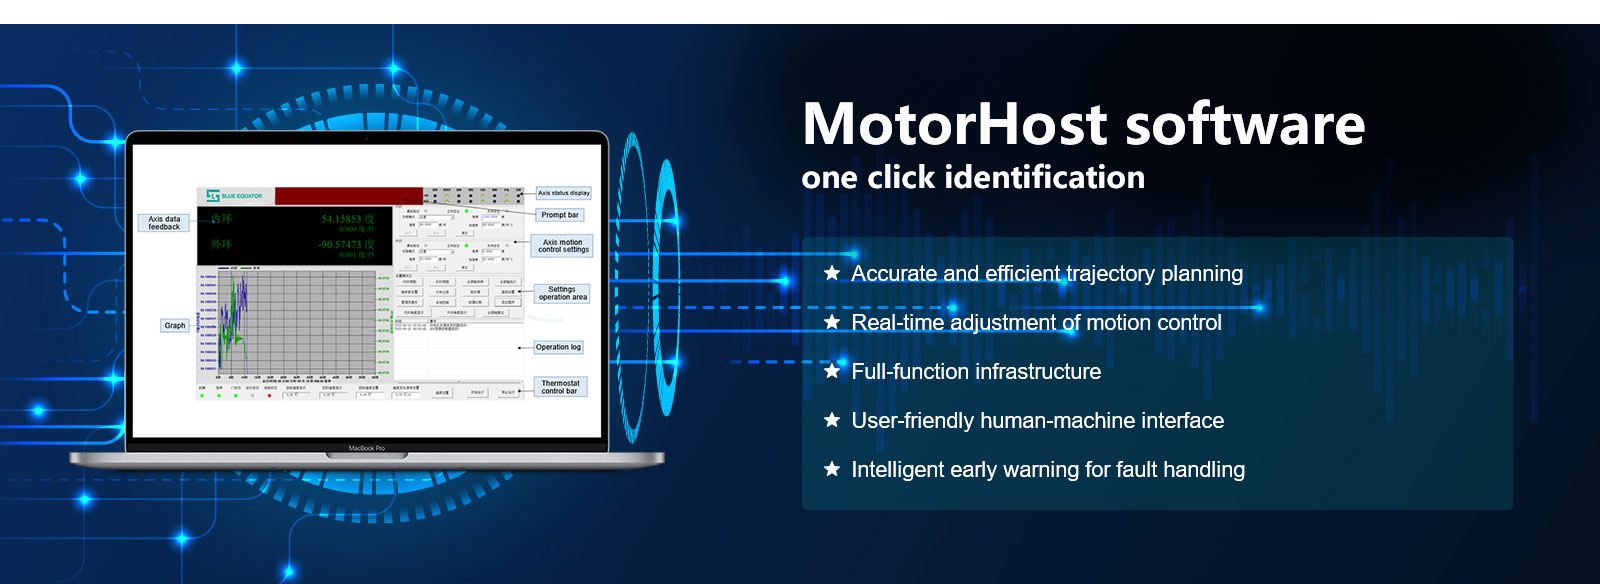
  • Automated control interface executing sensor experiment and data acquisition sequence
  • Precision dual axis motion simulator for construction survey and lab research on bench
  • U-T calibration stand with ⌀320mm alloy platform and marble isolation base for teaching
  • Close up of high precision encoder for ±3 arcsec accuracy and ±2 arcsec repeatability
  • Motion simulator performing low speed drift test for engineering sensor calibration
  • Test equipment dimensions with 10kg capacity on research laboratory workbench
  • Automated control interface executing sensor experiment and data acquisition sequence

Precision Motion Simulator for Construction Survey and Lab Research

No.BE-INS2-26A04
This precision dual axis motion simulator functions as gyro calibration fixture and sensor test stand for construction surveying and research laboratory applications. U-T structure with continuous 360° dual axis rotation supports full attitude sensor calibration for foundation inspection, tunnel guidance, and bridge monitoring equipment. Perfect for inertial tech demos, sensor calibration, motion control research & engineering measurement validation.
Specifications
Maximum load dimensions:
⌀300 mm × 180 mm (height)
Rated load capacity:
10 kg
Dual-axis angular positioning accuracy:
±3″
Download
View all downloads
  • Precision dual axis motion simulator for construction survey and lab research on bench
  • U-T calibration stand with ⌀320mm alloy platform and marble isolation base for teaching
  • Close up of high precision encoder for ±3 arcsec accuracy and ±2 arcsec repeatability
  • Motion simulator performing low speed drift test for engineering sensor calibration
  • Test equipment dimensions with 10kg capacity on research laboratory workbench
  • Automated control interface executing sensor experiment and data acquisition sequence

Description

1. Mechanical Structure & Mounting Table
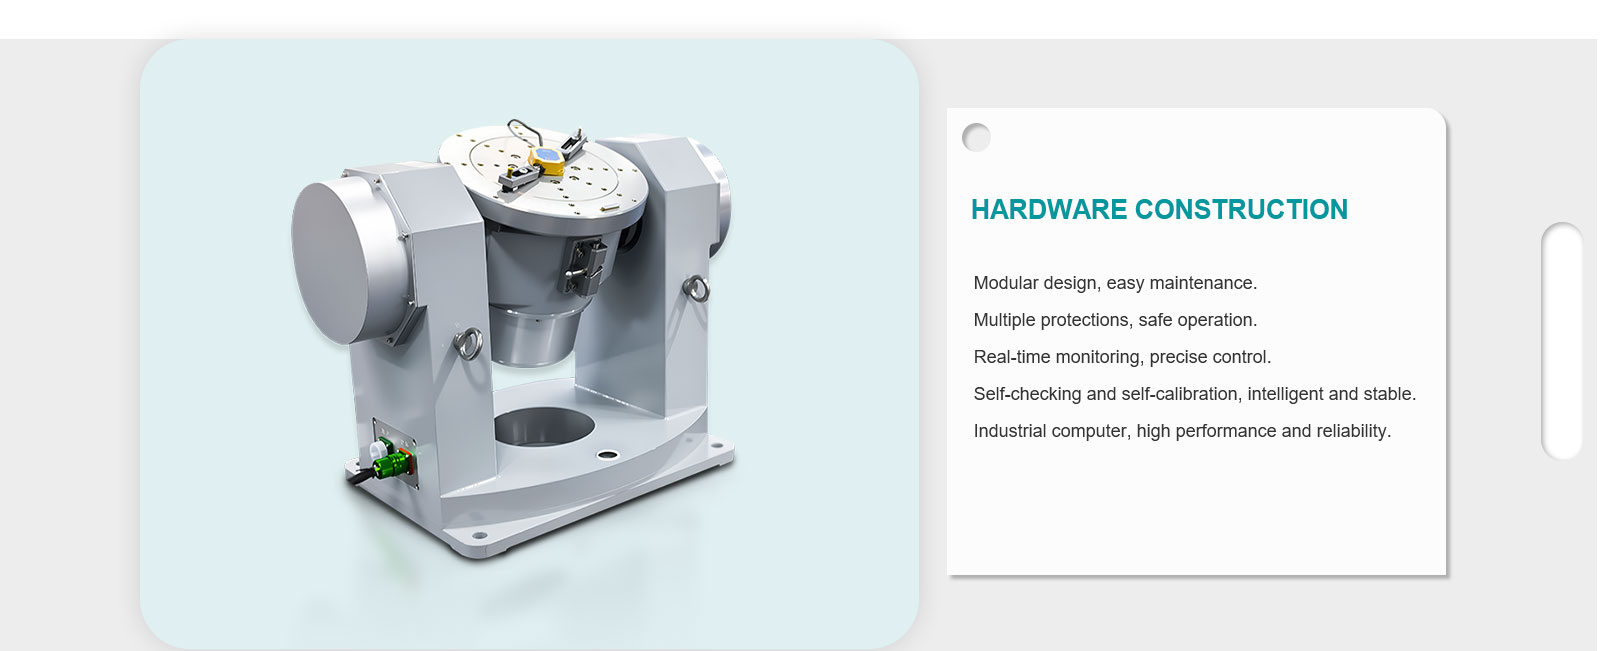
Outer frame (gimbal) structure "U" type frame, rotates about horizontal axis, capable of continuous 360° rotation
Inner frame structure "T" type structure, rotates about axis perpendicular to outer frame, continuous 360° rotation
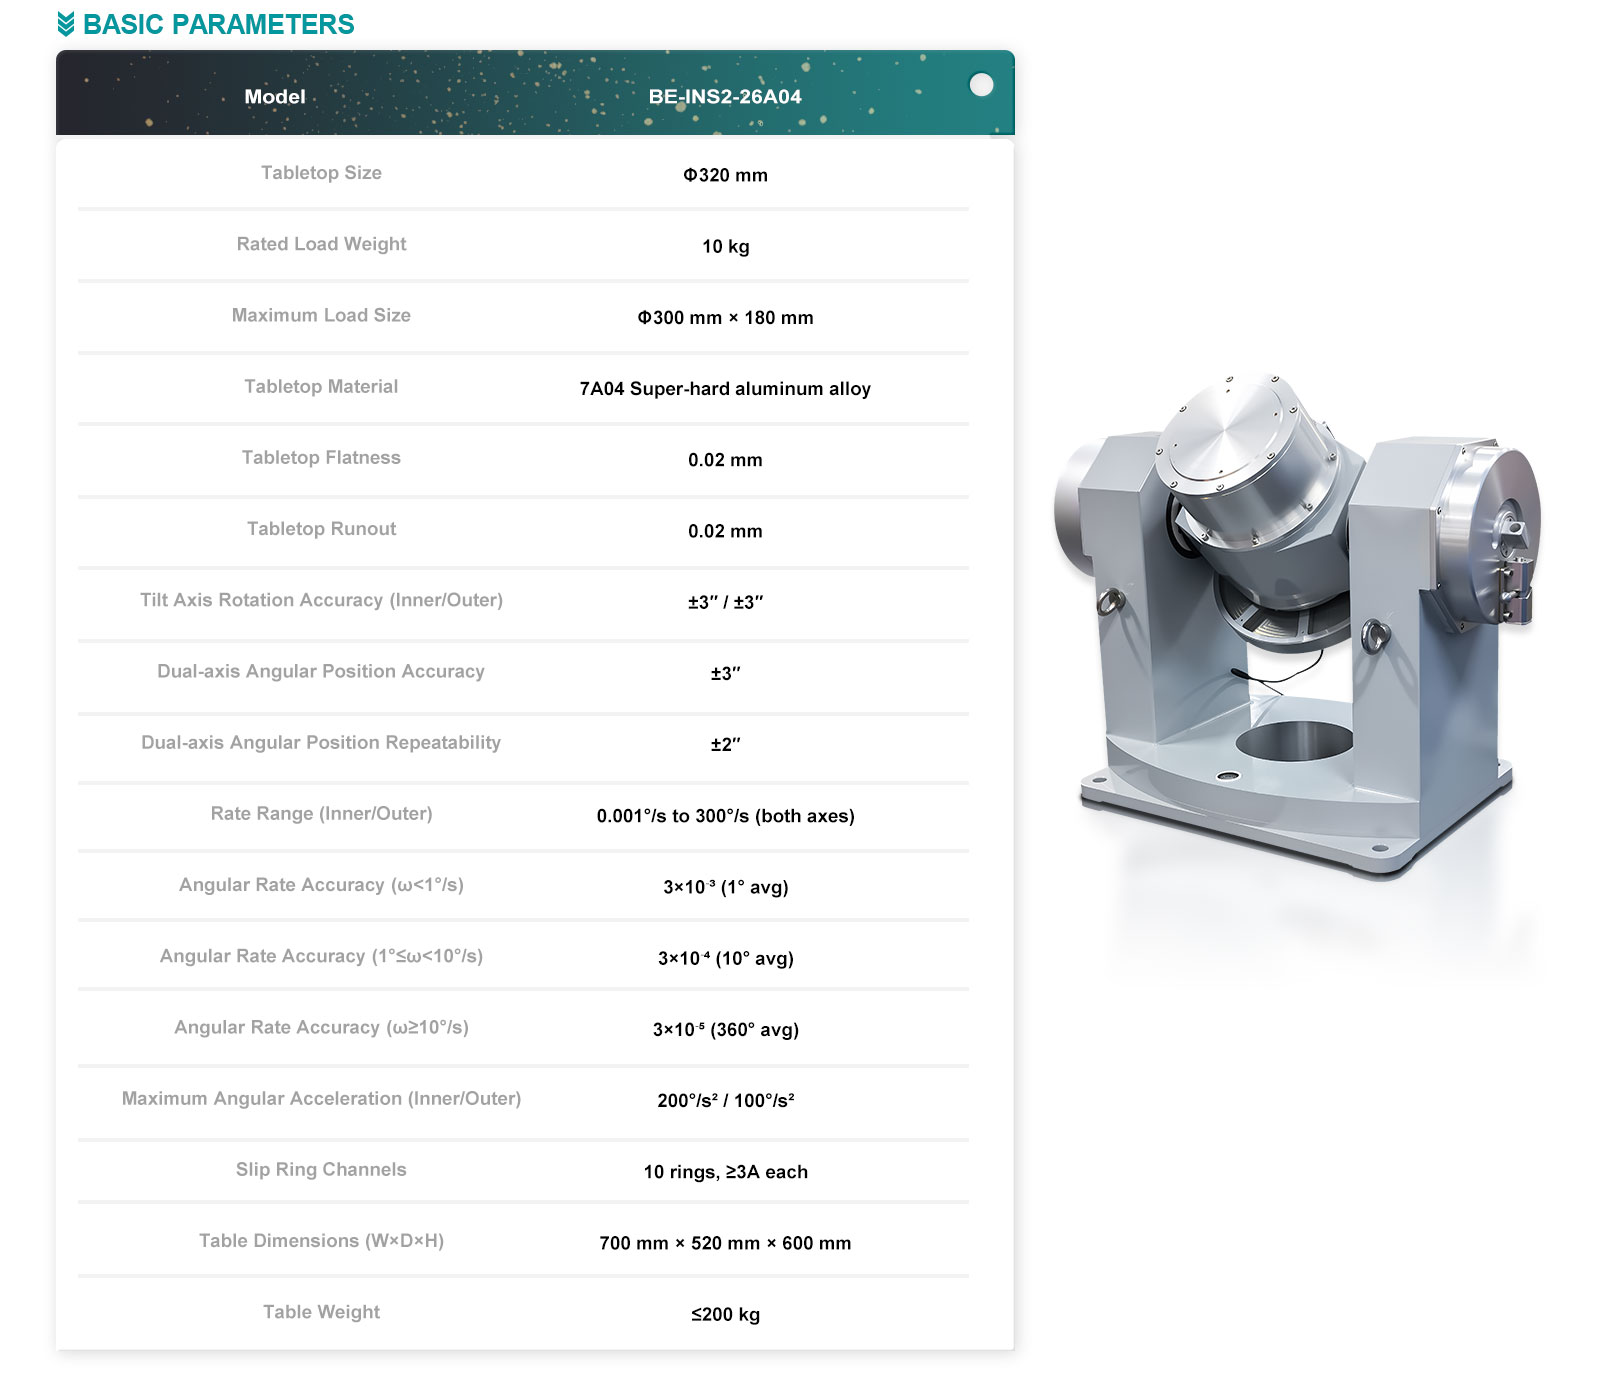
Maximum load dimensions ⌀300 mm × 180 mm (height)
Rated load capacity 10 kg
Table material 7A04 super-hard aluminum alloy
Table flatness 0.02 mm
Table runout (axial / end face) 0.02 mm
Table diameter ⌀320 mm
Granite base plate dimensions 1000 mm × 750 mm
2. Accuracy & Angular Positioning Performance
Tilt (wobble) accuracy / rotation precision Inner frame: ±3 arcsec (″), Outer frame: ±3 arcsec (″)
Dual-axis angular positioning accuracy ±3 arcsec (″)
Dual-axis angular positioning repeatability ±2 arcsec (″)
Maximum angular acceleration Inner frame: 200 °/s², Outer frame: 100 °/s²
Rate range (each axis) Inner frame: 0.001 °/s ~ 300 °/s
Outer frame: 0.001 °/s ~ 300 °/s
3. Angular Rate Accuracy & Rate Smoothness (Steady-State)
Rate accuracy
  • ω < 1 °/s : 3 × 10⁻³ (average over 1°)
  • 1 °/s ≤ ω < 10 °/s : 3 × 10⁻⁴ (average over 10°)
  • ω ≥ 10 °/s : 3 × 10⁻⁵ (average over 360°)
Rate smoothness (rate stability)
  • ω < 1 °/s : 3 × 10⁻³ (average over 1°)
  • 1 °/s ≤ ω < 10 °/s : 3 × 10⁻⁴ (average over 10°)
  • ω ≥ 10 °/s : 3 × 10⁻⁵ (average over 360°)
4. Slip Ring Assembly
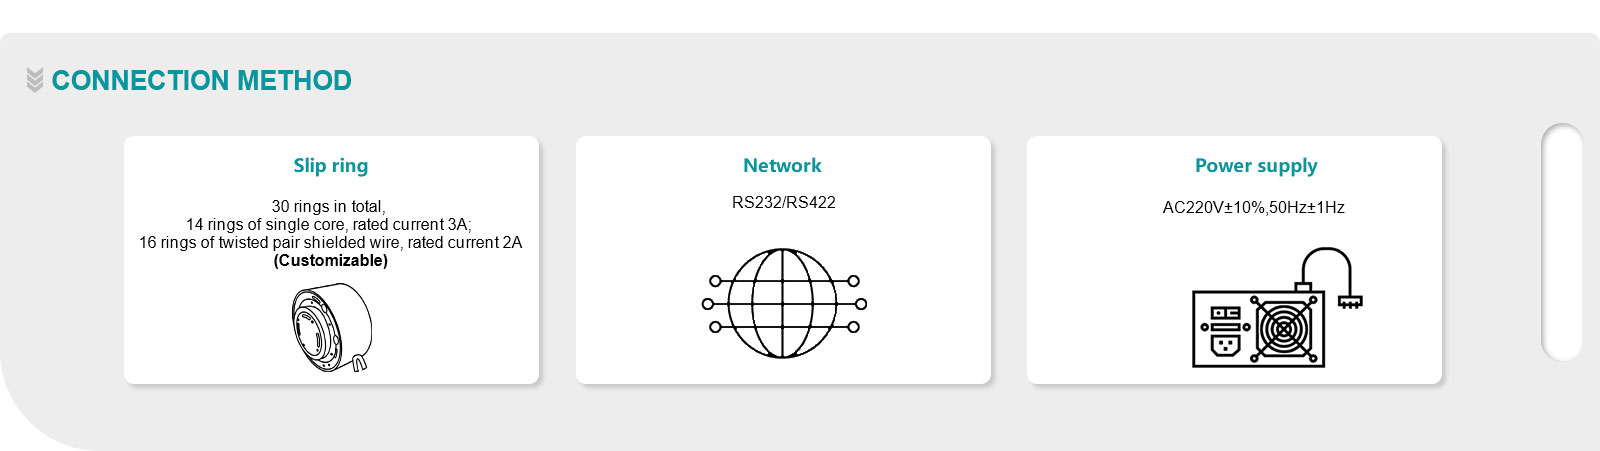
Number of user channels 10 channels
Current rating (per channel) ≥ 3 A
Contact resistance variation < 10 mΩ (change during rotation)
Slip ring operational life ≥ 1 × 10⁷ revolutions
5. Physical Dimensions & Weight
Overall dimensions (W × D × H) 700 mm × 520 mm × 600 mm
Total weight (turntable body) ≤ 200 kg